Currency
|

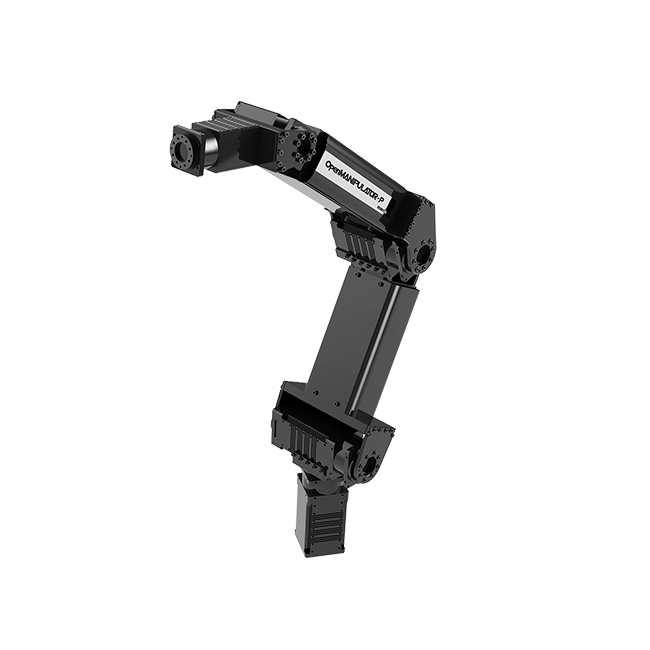
Product Name : OpenMANIPULATOR-P
Model Name : RM-P60-RNH
User Programmable Open-Source Manipulator System
Modular Platform for Easy Maintenance and Customization
No External Control Box & High Weight-to-Payload Ratio
| OpenMANIPULATOR-P | 1 (Fully-assembled) |
|---|---|
| Hard Case | 1 |
| U2D2 | 1 |
| Spare Cables (4P, 2P) | 1 |
| Screw Sets (WB M3x8 etc) | 1 |
| 4P Expansion Hub | 1 |
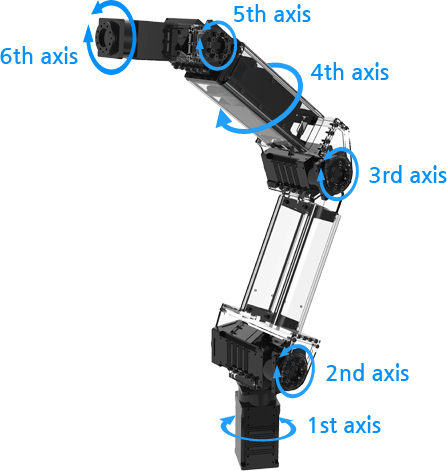
| DOF | 6 |
|---|---|
| Payload (kg) | 3 |
| Repeatability (mm) | ±0.05 |
| Speed (Each joint, deg/sec) | 180 |
| Weight (kg) | 5.76 |
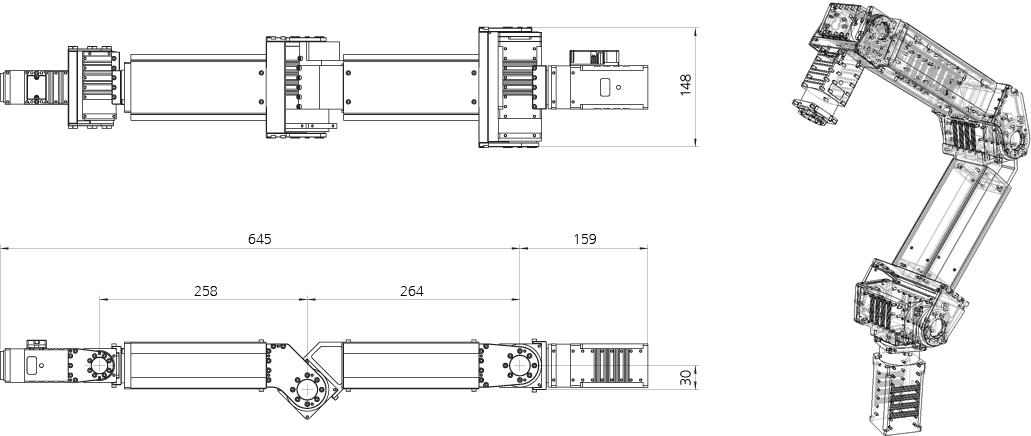
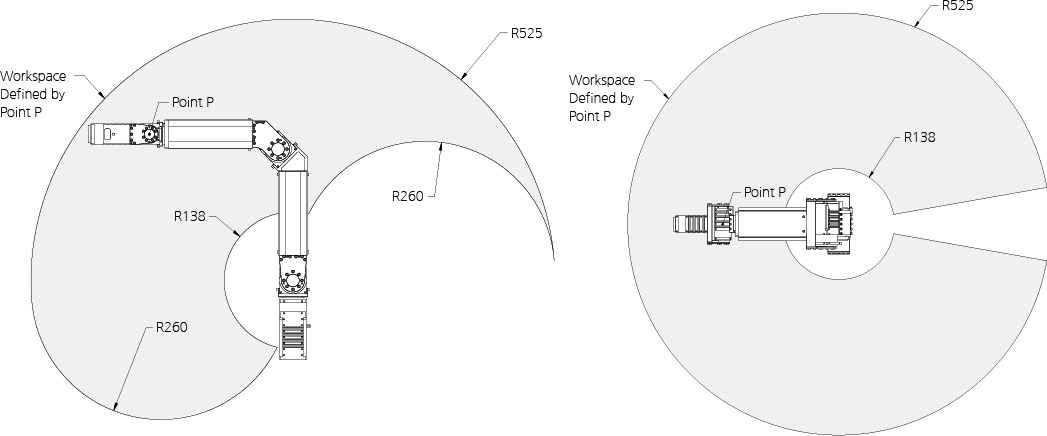
| Reach (mm) | 645 |
| Rated Voltage (VDC) | 24 |
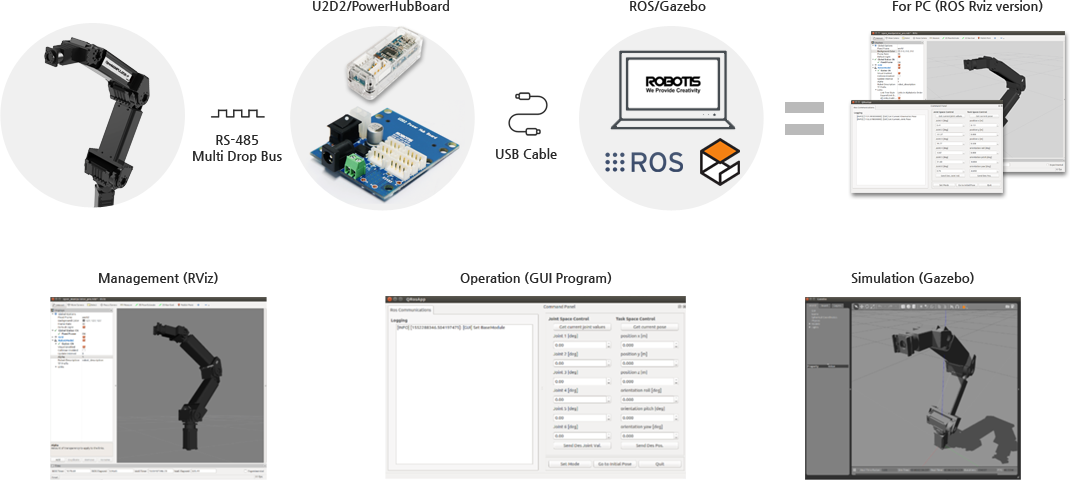
| Communication | RS-485 (Multi Drop Bus) |
| Motor Output / Joint | 200W / 2ea 100W / 2ea 20W / 2ea |
| Software | ROS (Ubuntu Linux) |
| Controller | PC (Not Included) |
ROBOTIS Manipulator controller package based on integrated software
OpenMANIPULATOR-P Library (Kinematics,Trajectory and Dynamixel Controller).
GUI program package for setting and monitoring control parameters.
MoveIt! package for OpenMANIPULATOR-P
Simulation package based on Gazebo Simulator
Teleoperation examples of keyboard and Joystick
Research and Education
Kinematics and Dynamics Experiment
Research and Design a Dual Arm Robot
Build a Mobile Robot System
Industrial Operation
Inspection Equipment
Small-Scale Delivery System
Power supply and PC are not included.
Please purchase separately according to your usage environment.
.
| ID | 1 |
|---|---|
| Baud Rate | 57600 bps |
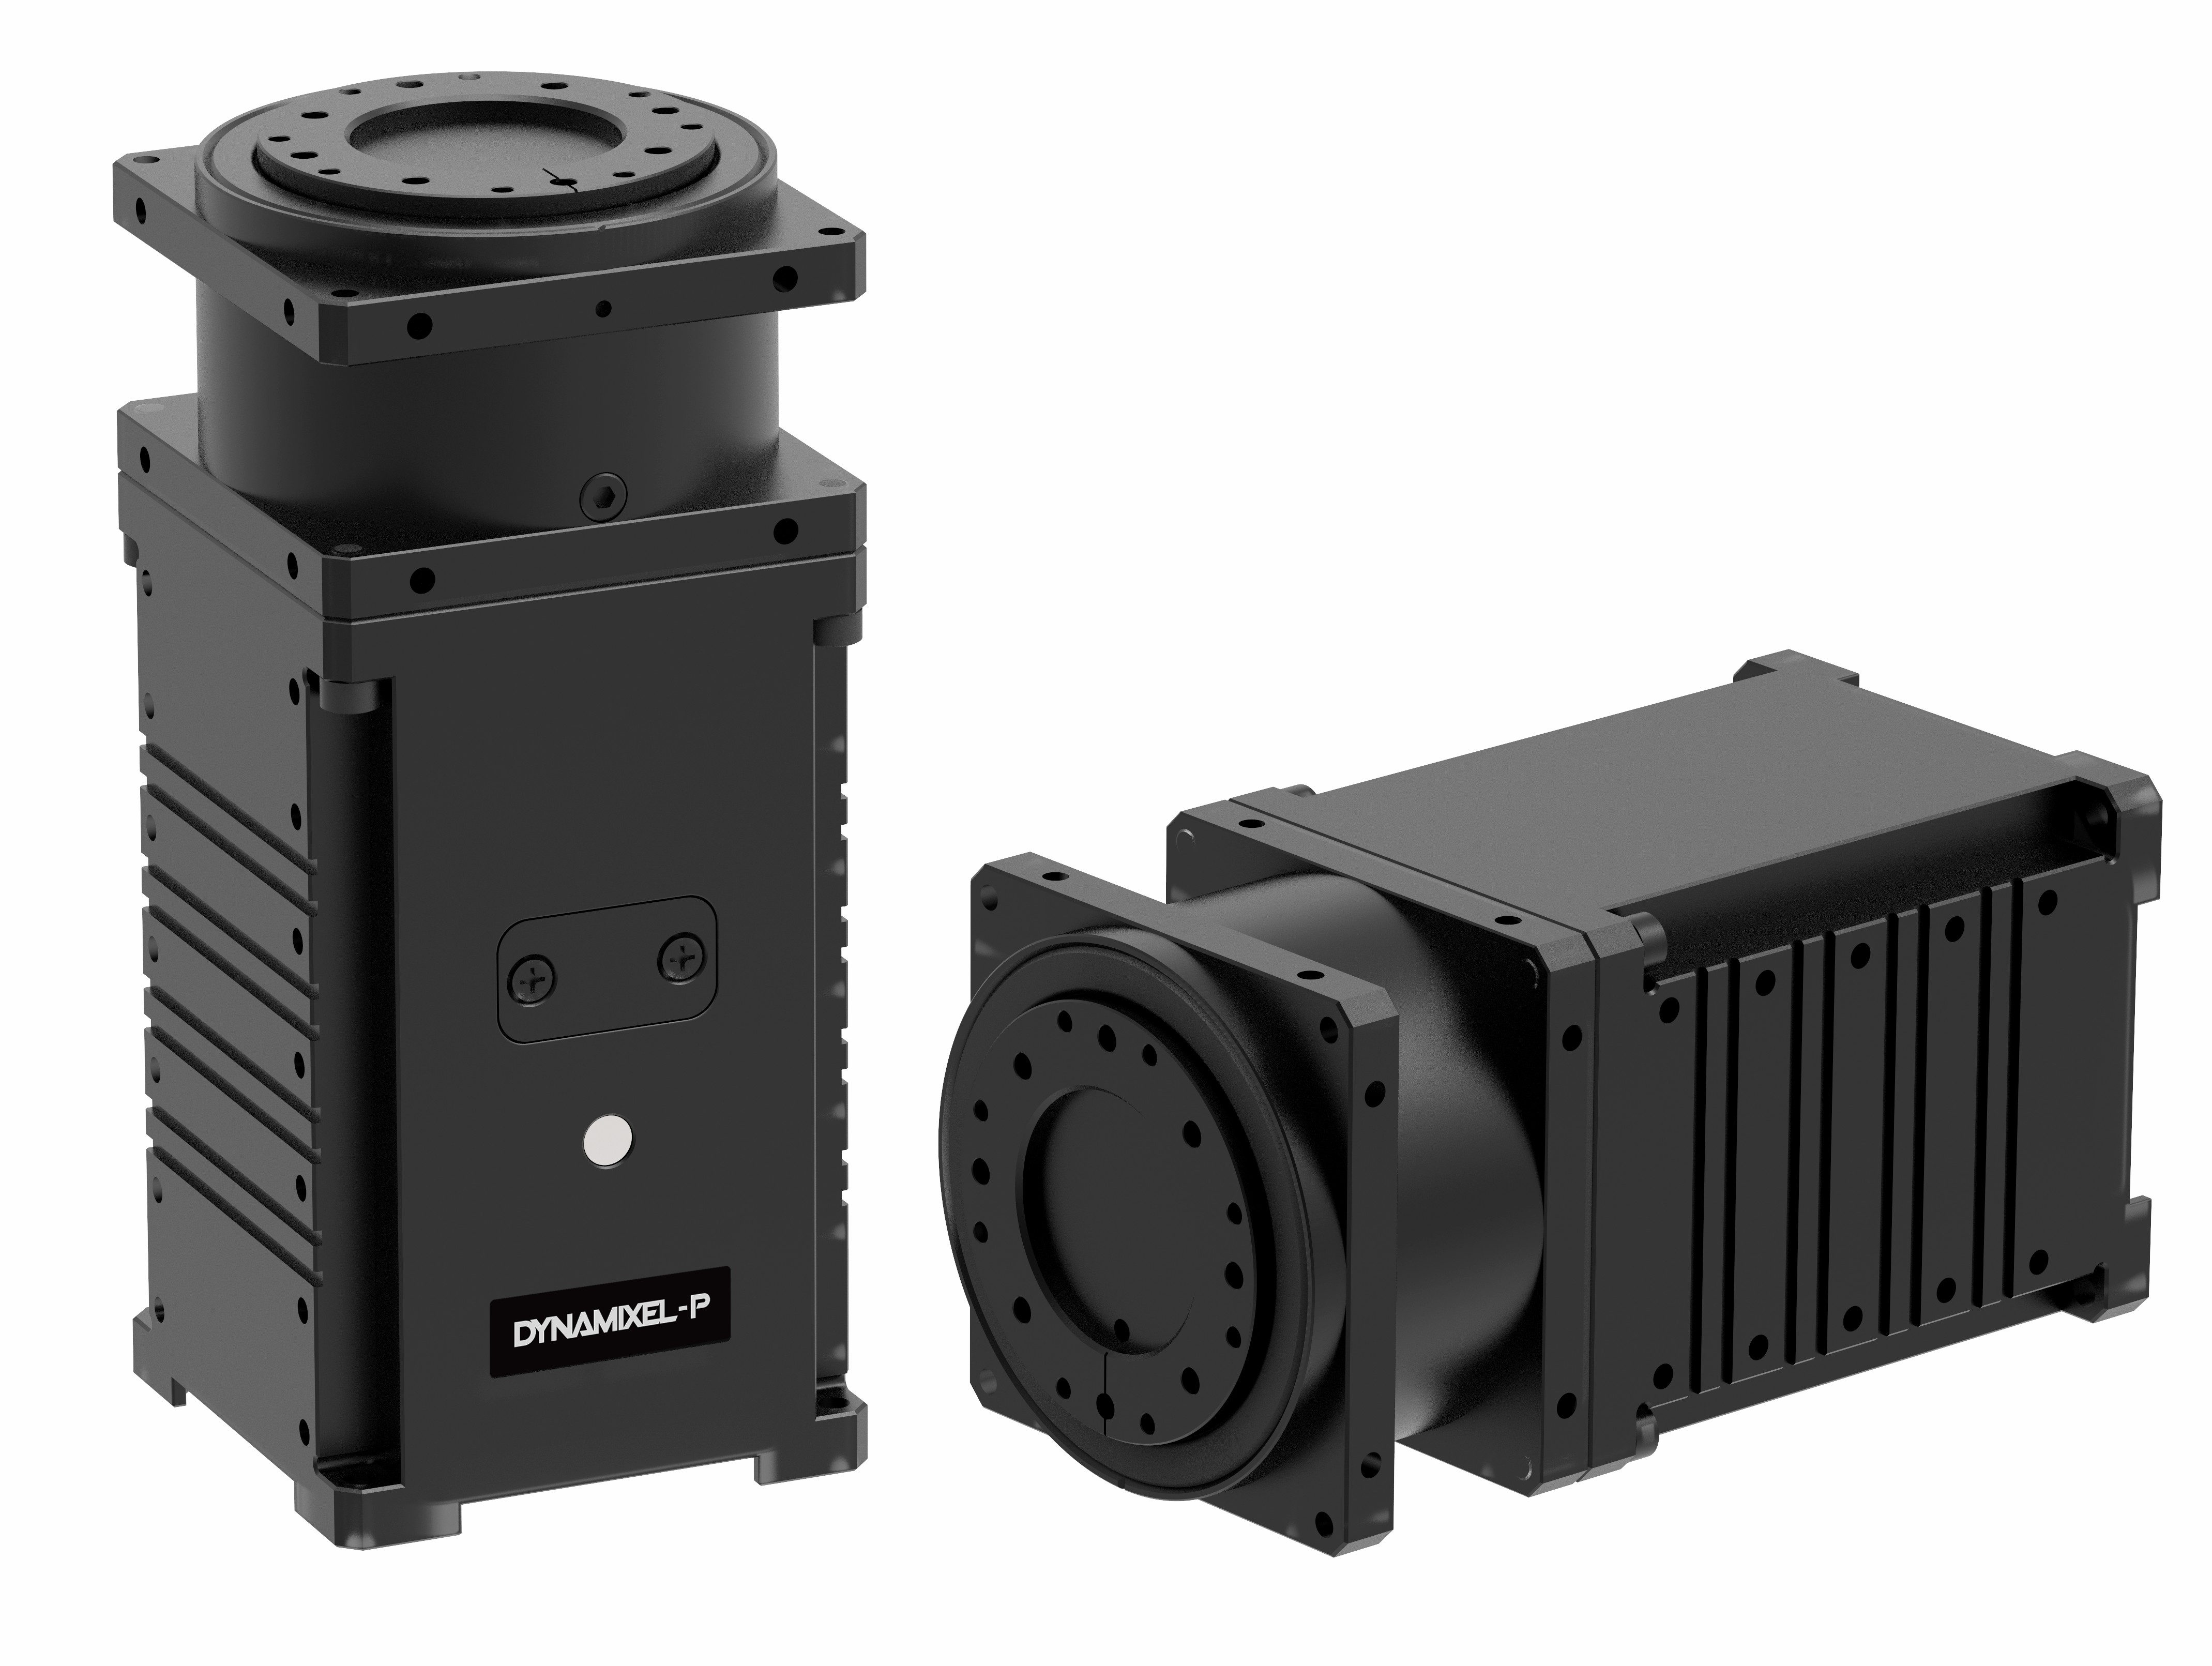
All-in-one Modular Design
DC Motor + Controller + Driver + Sensor + Cycloid Reduction Gear
Compact and Lightweight
Minimized module size with compact and lightweight cycloid reduction gear.
High weight-to-output ratio(0.05Nm/g)
High impact resistance ( over 400%)
High Precision and Low Backlash
Contactless (Magnetic) Absolute Encoder(by AMS) & Incremental Encoder for Precise Positioning
Low backlash (3~4arcmin)
Performance data provided tested by Korea Laboratory Accreditation Scheme(KOLAS)
Current-Based Torque Control
High speed current sensing algorithm and current feedback control
Triple-loop control for current, speed and position feedback.
User Friendly development environment
Provide C language based library
Various solution examples (C++, LabVIEW, C#, eclipse, JAVA, etc..)
| Manufacturer | Robotis |
|---|