Currency
|

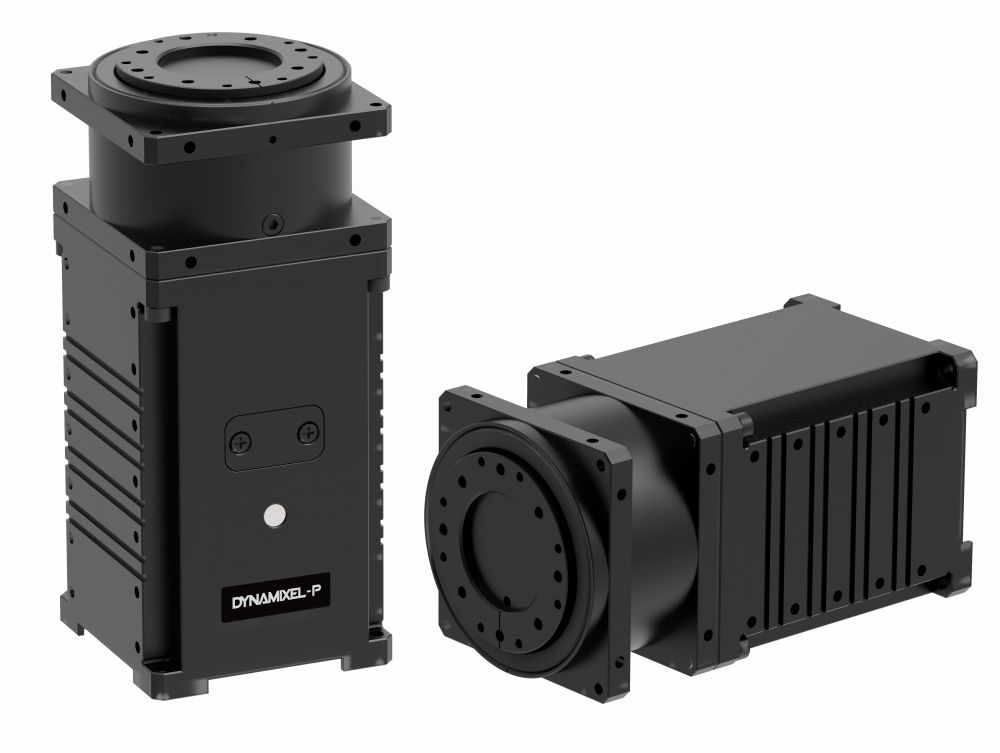
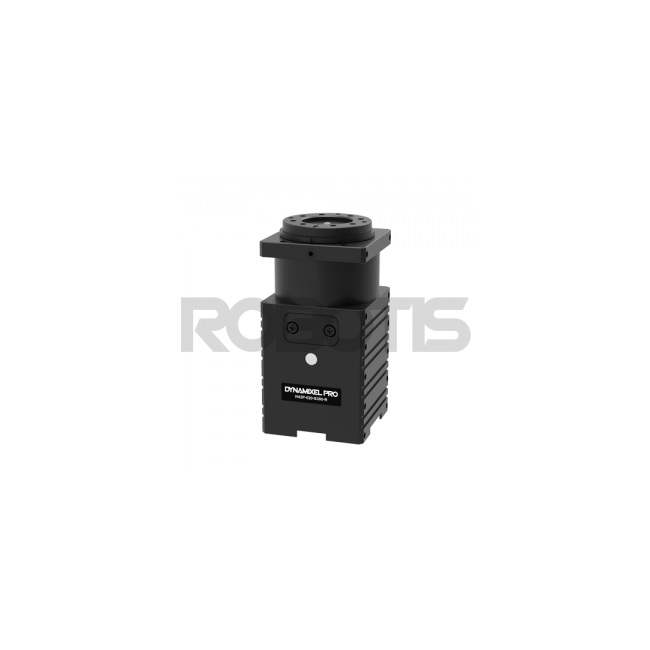
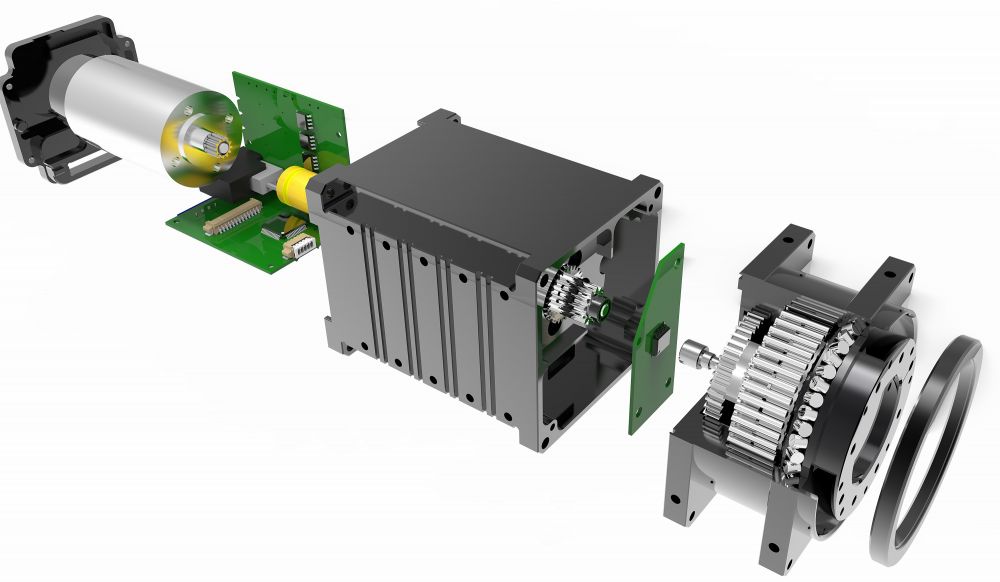
DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Controller + Driver + Sensor + Reduction Gear + Network in one DC servo module.
DYNAMIXEL-P Series implements removable reduction cycloid gears, resulting in high precision and impact resistance.
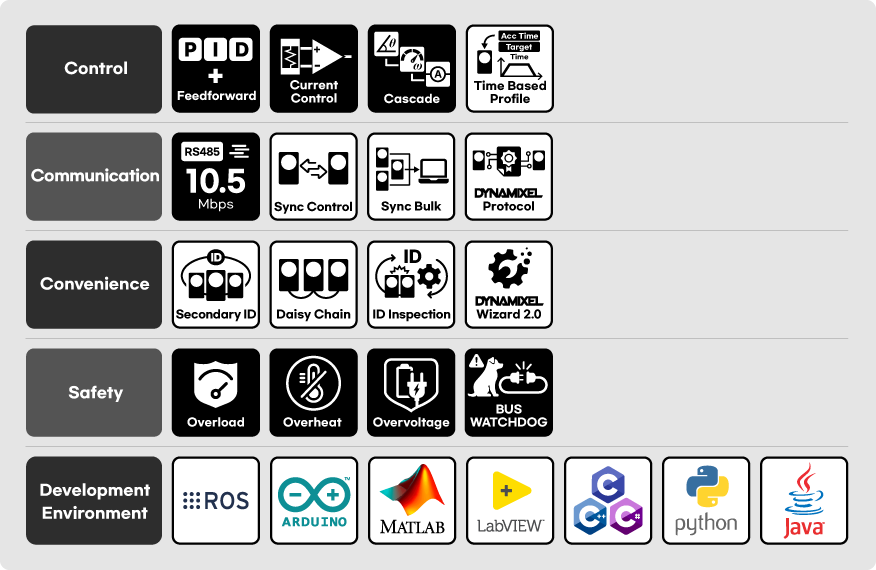
- Torque control based on current sensing
- Position, Torque and Speed-based command
- High resolution with combination of Incremental Encoder and Contactless Absolute Encoder
- Full metal housing for high durability
- Can be used to make a full-size manipulator, pan tilt, humanoid, etc.
[DYNAMIXEL PRO -> P] Upgrade Details
- Improved design and JST connectors applied
- Improved dirt inflow and leakage
- Improved control table (Supports X Series functions)
- Enhanced control performance such as responsiveness and resolution
- Enhanced communication responsiveness
- Improved heat, noise, and durability
| Item | Quantity | Description |
| PH42-020-S300-R | 1 | DYNAMIXEL |
| Robot Cable-X4P 300mm(Convertible) | 1 | RS485 4p Cable(MOLEX-JST) |
| Robot Cable-X4P 300mm | 1 | RS485 4p Cable(JST-JST) |
| Wrench Bolt WB M3x8 | 20 | For frame assembly |
The operational voltage is different from other DYNAMIXEL series (Operational voltage: 24V).
Depending on the number of units used, it is recommended to use a separate power supply.
JST 4Pin connector is applied for communication.
The 42 series uses the same hinge frames.(FRP42-H110/120)
| Model Name | PH42-020-S300-R | |
|---|---|---|
| Series | DYNAMIXEL P | |
| MCU | ARM Cortex-M4 (168 [Mhz], 32 [bit]) | |
| Input Voltage | Min. [V] | - |
| Recommended [V] | 24.0 | |
| Max. [V] | - | |
| Performance Characteristics | Voltage [V] | 24.0 |
| Stall Torque [N·m] | - | |
| Stall Current [A] | - | |
| No Load Speed [rpm] | 33.0 | |
| No Load Current [A] | 0.57 | |
| Continuous Operation *) | Voltage [V] | 24.0 |
| Torque [N·m] | 5.1 | |
| Speed [rpm] | 29.2 | |
| Current [A] | 1.5 | |
| Resolution | Resolution [deg/pulse] | 0.0006000000 |
| Step [pulse/rev] | 607,500 | |
| Angle [degree] | 360 | |
| Position Sensor | Contactless absolute encoder Incremental encoder | |
| Operating Temperature | Min. [°C] | -5 |
| Max. [°C] | 55 | |
| Motor | Coreless (Maxon) | |
| Baud Rate | Min. [bps] | 9,600 |
| Max. [bps] | 10,500,000 | |
| Control Algorithm | PID | |
| Gear Type | Cycloid | |
| Gear Material | Metal | |
| Case Material | Metal | |
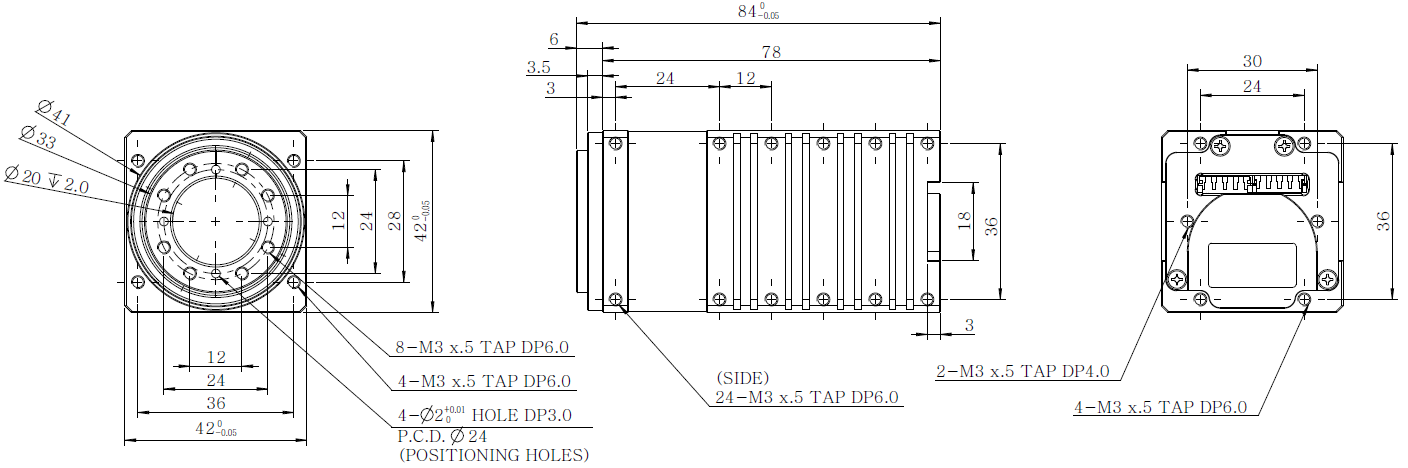
| Dimensions (WⅹHⅹD) [mm] | 42.0 x 84.0 x 42.0 | |
| Dimensions (WⅹHⅹD) [inch] | 1.65 x 3.31 x 1.65 | |
| Weight [g] | 340.00 | |
| Weight [oz] | 11.99 | |
| Gear Ratio | 303.8 : 1 | |
| Backlash [arcmin] | 6 | |
| Backlash [deg] | 0.10 | |
| Command Signal | Digital Packet | |
| Protocol Type | Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) | |
| Link (Physical) | RS-485 Multidrop Bus | |
| ID | 0 ~ 252 | |
| Feedback | Position, Velocity, Current, Temperature, Voltage, External Port, etc | |
| Protocol version | Protocol 2.0 Modbus | |
| Operating Mode / Angle | Current Control mode:Endless turn Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode PWM Control Mode:Endless turn | |
| Output [W] | 20 | |
| Standby Current [mA] | 30 | |
| Manufacturer | Robotis |
|---|